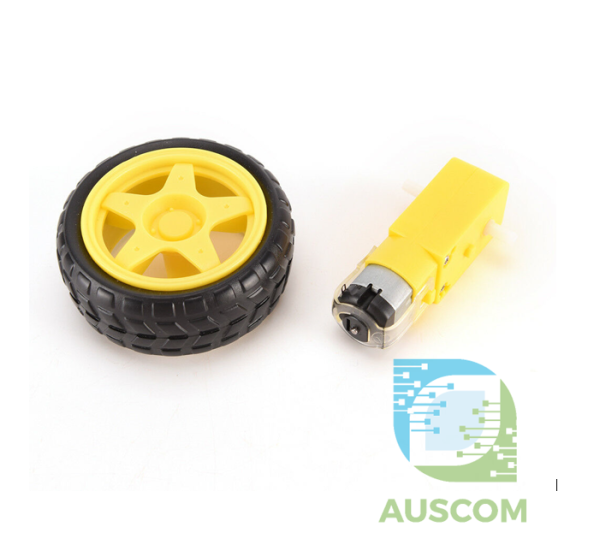
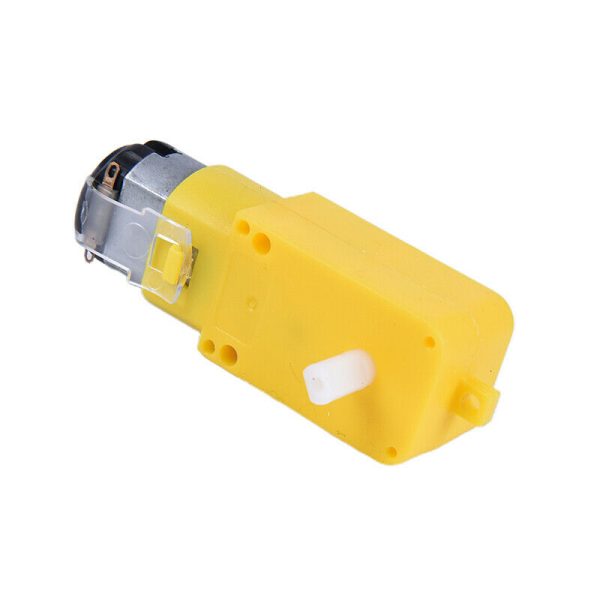
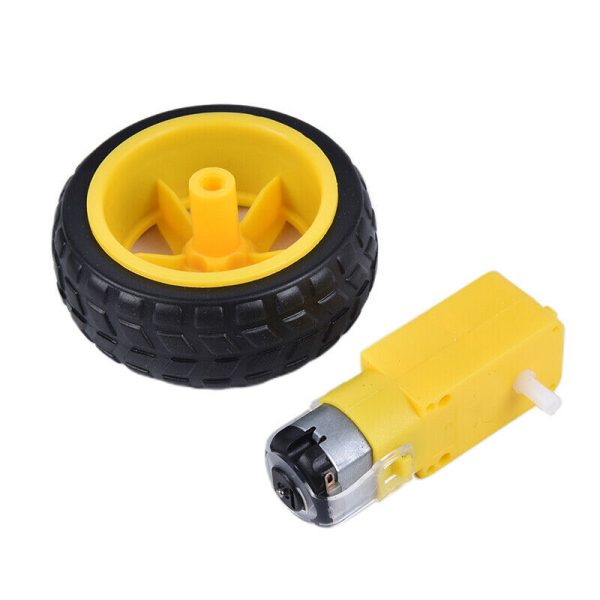
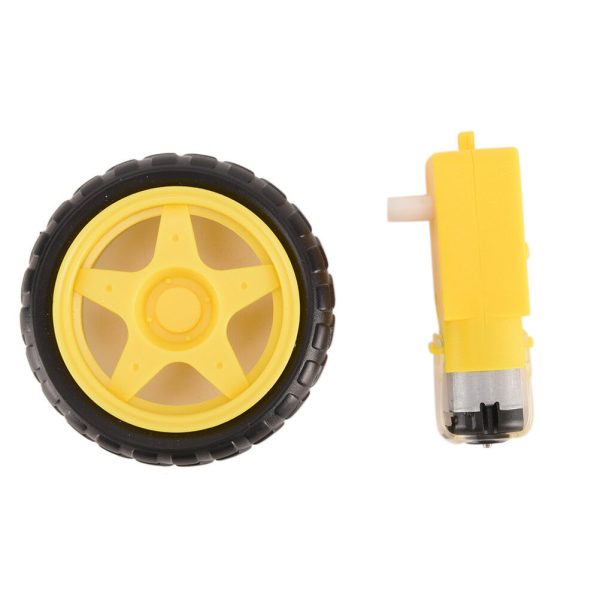
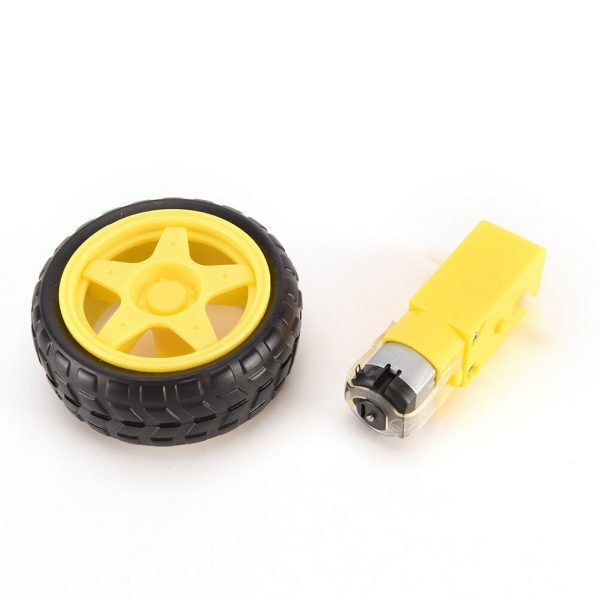
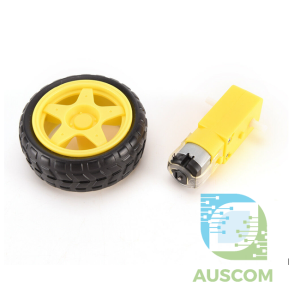

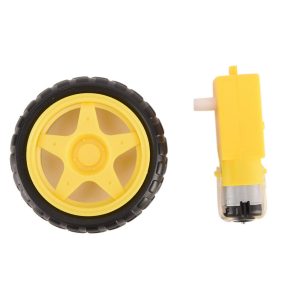
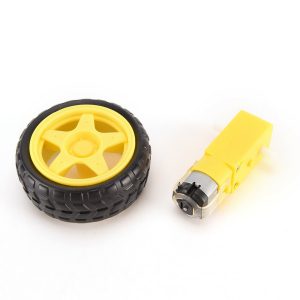
TT Motor Gear and Wheel Set DC 3–6V for Arduino Robot Smart Car
$12.50 Inc. GST
You save
- Description
- Code Examples
- Additional information
- Reviews (0)
Description
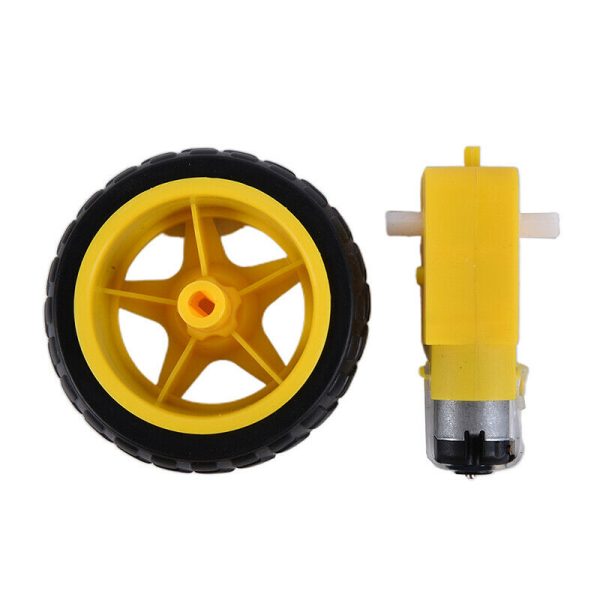
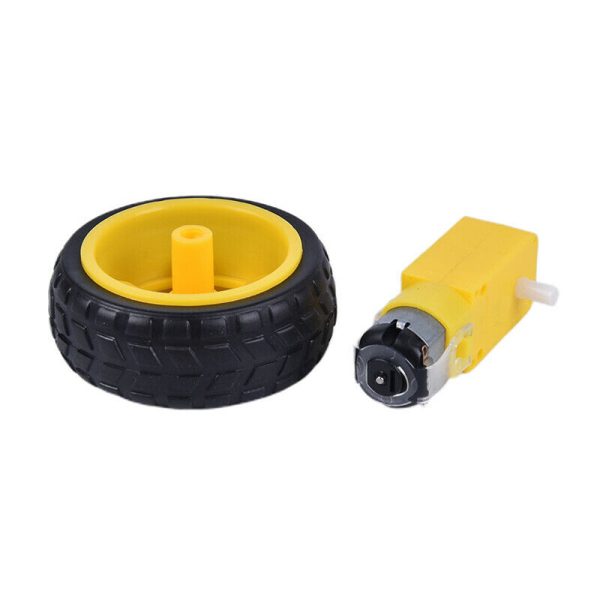
🚗 TT Motor Gear & Wheel Set – DC Gear Motor with Wheel for Arduino & Robot Cars | AuscomTech
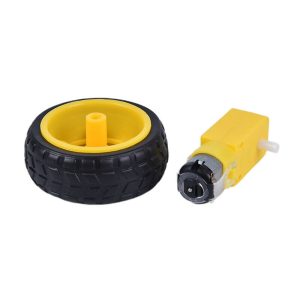
The TT Motor Gear and Wheel Set is a reliable and widely used drive solution for robot cars, smart vehicles, and DIY robotics projects.
Designed for simplicity, efficiency, and compatibility, this DC geared motor with matching wheel is ideal for Arduino, Raspberry Pi, ESP32, and educational robotics platforms.
Perfect for beginners, students, and makers building mobile robots, line-followers, and autonomous vehicles.
⭐ Key Features
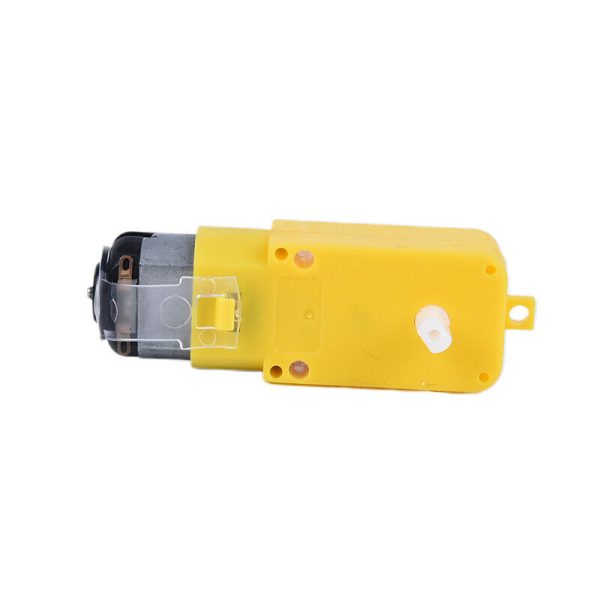
⚙️ Integrated DC Gear Motor (TT Type)
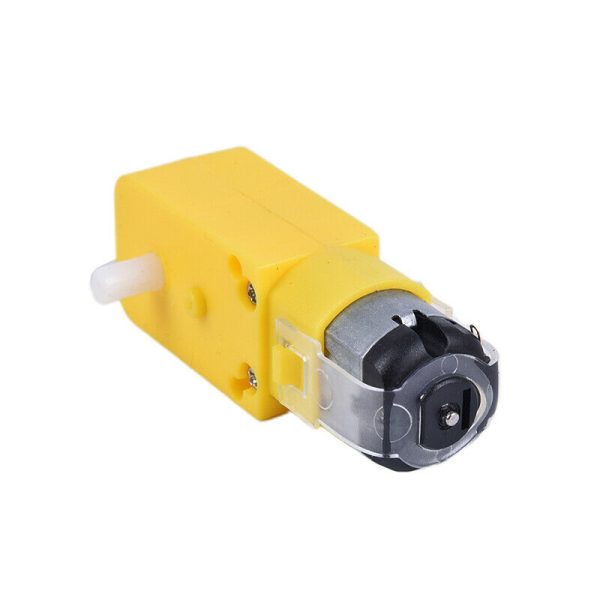
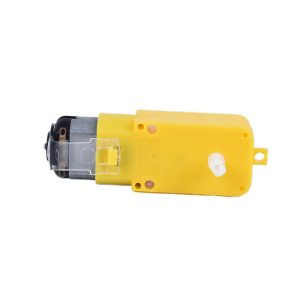
Compact brushed DC motor with built-in gearbox for increased torque and controlled speed.
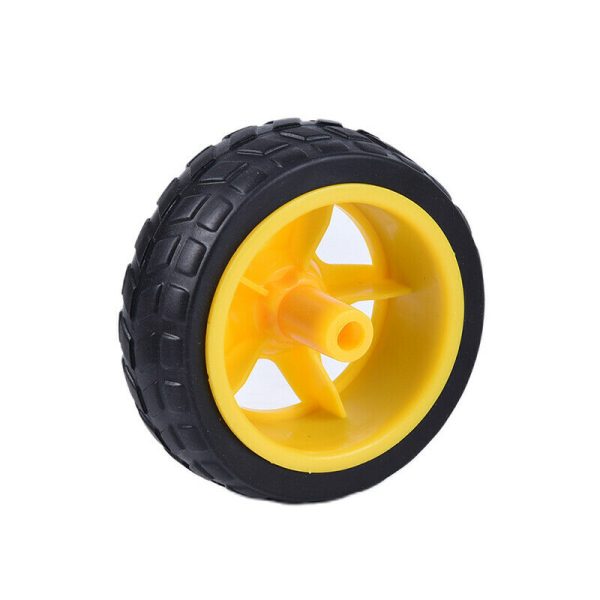
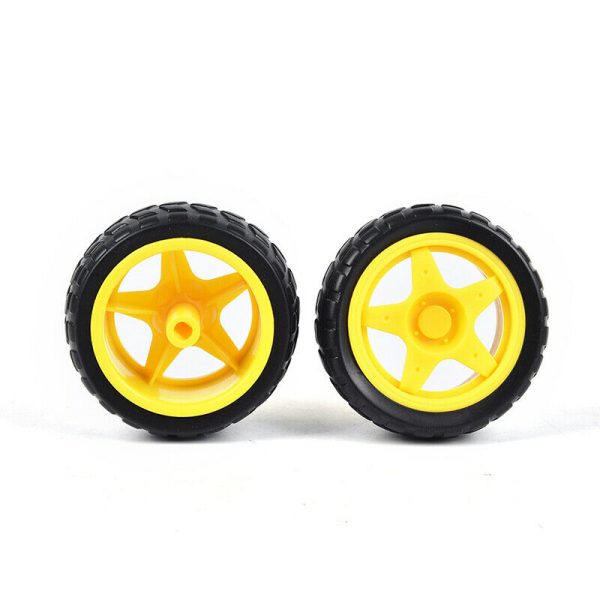
🚙 Matched Drive Wheel Included
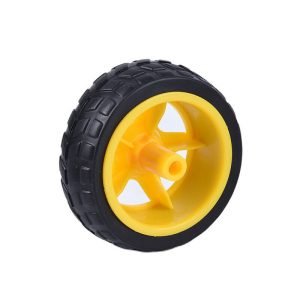
66mm diameter wheel provides good traction and stability for robot chassis and smart car kits.
🔌 Low-Voltage Operation (3–6V)
Safe and compatible with common battery packs, motor drivers, and microcontroller projects.
🧠 Microcontroller Friendly
Works seamlessly with Arduino, Raspberry Pi (via motor driver), ESP8266, ESP32, and STM32 systems.
🛠️ Pre-Wired Motor Leads
Positive and negative wires are pre-soldered for quick and easy installation.
📚 Ideal for Learning & Prototyping
Widely used in STEM education, robotics kits, and DIY experimentation.
📊 Technical Specifications
| Specification | Details |
|---|---|
| Motor Type | DC brushed motor with gearbox (TT motor) |
| Operating Voltage | 3V – 6V DC |
| Gear Ratio | 1:48 |
| No-Load Speed | ~200 RPM @ 5V |
| No-Load Current | ~190 mA @ 5V |
| Rated Torque | ~78 mN·m (≈0.8 kgf·cm) |
| Motor Dimensions | 70 × 36.5 × 24.5 mm |
| Wheel Diameter | 66 mm |
| Wheel Thickness | 25 mm |
| Net Weight | ~65 g |
🧩 Compatible With
• Arduino Uno / Nano / Mega
• Raspberry Pi (with motor driver)
• ESP8266 / ESP32
• L298N, L293D, TB6612 motor drivers
• Smart car chassis kits
• Educational robotics platforms
🔧 Typical Applications
• Smart robot cars
• Line-following robots
• Obstacle-avoiding robots
• Arduino & Raspberry Pi robotics projects
• STEM education kits
• DIY mobile platforms
• Small autonomous vehicles
⚠️ Usage Notes
• Motor driver required when using microcontrollers
• Do not exceed rated voltage to prevent gear wear
• Suitable for light-duty robotics and learning projects
📦 Package Includes
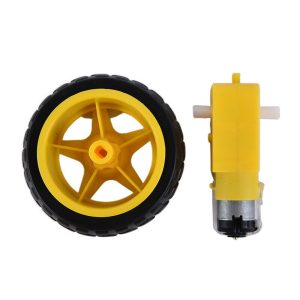
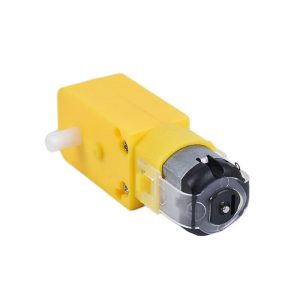
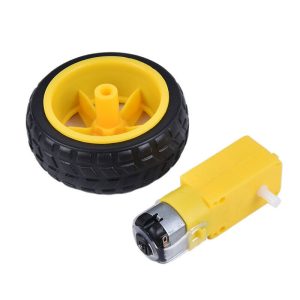
• 1 × TT DC Gear Motor (yellow/white) with pre-wired leads
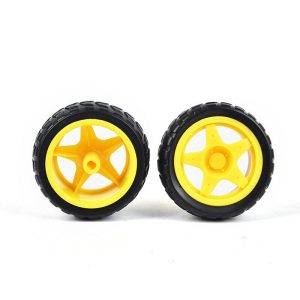
• 1 × Matching Wheel (yellow/black)
📌 Code Examples & Usage – TT Motor Gear Wheel
DC Gear Motor for Arduino, Raspberry Pi & Robot Cars
📋 Overview
The TT motor is a low-cost DC gear motor commonly used in:
Robot cars & boats
Line followers
Smart vehicles
Educational STEM projects
Prototypes and small mechanisms
⚠ Important:
This motor cannot be driven directly from a microcontroller pin.
You must use a motor driver (L298N, L293D, TB6612FNG, relay, or MOSFET).
🔌 Power & Driver Basics
Typical TT motor specs:
Voltage: 3–6 V DC
Current: up to 300–800 mA under load
Direction: reversible by polarity swap
Common Motor Driver Options
Driver Good for
L298N Beginner robot cars
L293D Small loads
TB6612FNG Efficient, compact
MOSFET One-direction control
Relay Simple on/off
🔧 Wiring Example – L298N Motor Driver (Most Common)
Single Motor Wiring
L298N Connects To
OUT1 / OUT2 TT Motor terminals
IN1 Arduino pin 8
IN2 Arduino pin 9
ENA Arduino pin 10 (PWM)
+12V Motor supply (6–7V recommended)
GND Arduino GND
⚠ Always share GND between Arduino and motor driver.
🧪 1️⃣ Arduino Example – Motor Forward / Reverse
const int IN1 = 8;
const int IN2 = 9;
const int ENA = 10; // PWM pin
void setup() {
pinMode(IN1, OUTPUT);
pinMode(IN2, OUTPUT);
pinMode(ENA, OUTPUT);
}
void loop() {
// Forward
digitalWrite(IN1, HIGH);
digitalWrite(IN2, LOW);
analogWrite(ENA, 200); // speed (0–255)
delay(2000);
// Stop
analogWrite(ENA, 0);
delay(500);
// Reverse
digitalWrite(IN1, LOW);
digitalWrite(IN2, HIGH);
analogWrite(ENA, 200);
delay(2000);
// Stop
analogWrite(ENA, 0);
delay(1000);
}
🎚 2️⃣ Arduino Example – Speed Control (PWM Ramp)
void loop() {
digitalWrite(IN1, HIGH);
digitalWrite(IN2, LOW);
// Ramp up speed
for (int speed = 0; speed = 0; speed -= 5) {
analogWrite(ENA, speed);
delay(30);
}
}
Great for smooth starts and stops.
🚗 3️⃣ Robot Car Example – Two TT Motors
Used in 2WD robot cars (left + right motor).
// Left motor
const int L_IN1 = 8;
const int L_IN2 = 9;
const int L_EN = 10;
// Right motor
const int R_IN1 = 6;
const int R_IN2 = 7;
const int R_EN = 5;
void setup() {
pinMode(L_IN1, OUTPUT);
pinMode(L_IN2, OUTPUT);
pinMode(L_EN, OUTPUT);
pinMode(R_IN1, OUTPUT);
pinMode(R_IN2, OUTPUT);
pinMode(R_EN, OUTPUT);
}
void forward(int speed) {
digitalWrite(L_IN1, HIGH);
digitalWrite(L_IN2, LOW);
digitalWrite(R_IN1, HIGH);
digitalWrite(R_IN2, LOW);
analogWrite(L_EN, speed);
analogWrite(R_EN, speed);
}
void stopMotors() {
analogWrite(L_EN, 0);
analogWrite(R_EN, 0);
}
void loop() {
forward(180);
delay(2000);
stopMotors();
delay(1000);
}
⚡ ESP32 Example – TT Motor Control
ESP32 uses hardware PWM (LEDC).
const int IN1 = 18;
const int IN2 = 19;
const int ENA = 5;
void setup() {
pinMode(IN1, OUTPUT);
pinMode(IN2, OUTPUT);
ledcSetup(0, 5000, 8); // channel, freq, resolution
ledcAttachPin(ENA, 0);
}
void loop() {
digitalWrite(IN1, HIGH);
digitalWrite(IN2, LOW);
ledcWrite(0, 200); // speed
delay(2000);
ledcWrite(0, 0); // stop
delay(1000);
}
🧠 Tips & Best Practices
✔ Use separate motor power from logic where possible
✔ Add bulk capacitors (470–1000 µF) on motor supply
✔ Motors generate electrical noise — keep wires short
✔ If motor spins backwards, just swap the motor wires
✔ For boats: add shaft sealing and corrosion protection
Additional information
| Weight | 100 g |
|---|---|
| Dimensions | 260 × 160 × 20 mm |
Only logged in customers who have purchased this product may leave a review.


Reviews
There are no reviews yet.